 AIR ROBOTICS
Of mined land waiting to be cleared in Ukraine alone.
AV-RX Mk.II
A robotic teammate for every soldier.Un coéquipier robotique pour chaque soldat.
A tactical humanoid designed and built in Europe. It carries, it shields, it keeps going and it shares what it sees, wherever sending a human costs too much.Un humanoïde tactique conçu et fabriqué en Europe. Il porte, il protège, il tient dans la durée et il partage ce qu’il voit, là où envoyer un humain coûte trop cher.
20 km/hSustained running on broken groundCourse soutenue sur terrain accidenté
8 hContinuous operational enduranceAutonomie opérationnelle continue
15NATO-standard modules, hot-swapped under 10 sModules au standard OTAN, échange à chaud en moins de 10 s
92%European content by value, ITAR-freeDe valeur européenne, hors périmètre ITAR
The problemLe besoin
Today's machines cannot walk into our buildings.Les machines actuelles n’entrent pas dans nos bâtiments.
Tracked platforms and quadrupeds hit the same wall: they cannot use infrastructure and equipment built for people. Doors, stairs, ladders, vehicles, handles, hand tools. An anthropomorphic robot uses all of it as it is, with no adaptation and no retrofit.Chenillés et quadrupèdes butent sur la même limite : ils ne peuvent pas utiliser les infrastructures et les équipements conçus pour des humains. Portes, escaliers, échelles, véhicules, poignées, outils à main. Un robot anthropomorphe s’en sert tels quels, sans adaptation ni modification.
Meanwhile European armies are shrinking. France is heading for 200,000 service members by 2030, down from 270,000 in 1990. The Bundeswehr is running 15% short of its recruitment targets. The British Army is at its smallest since 1714. On high-exposure tasks, one AV-RX stands in for three to four soldiers.Dans le même temps, les armées européennes se réduisent. La France vise 200 000 militaires en 2030 contre 270 000 en 1990. La Bundeswehr manque 15 % de ses objectifs de recrutement. La British Army est au plus bas depuis 1714. Sur les missions à forte exposition, un AV-RX prend la place de trois à quatre soldats.
De terres minées à traiter pour la seule Ukraine.
Operating tempo with no fatigue, no rotation and no relief.
Rythme d’engagement sans fatigue, sans rotation ni relève.
Radiation levels the machine can enter and a person cannot.
Niveau de rayonnement où la machine entre et où l’humain ne peut pas.
European manufacturer has industrialised a tactical humanoid yet.
Industriel européen n’a encore industrialisé d’humanoïde tactique.
AV-RX Mk.II
180 cm, 95 kg, carried by two soldiers.180 cm, 95 kg, porté par deux soldats.
Under 100 kg, the robot moves like a piece of equipment rather than a vehicle. It can be air-dropped, it clears a standard doorway, it climbs an ordinary staircase and it handles the standard-issue objects already in the inventory.Sous les 100 kg, le robot se déplace comme un équipement, pas comme un véhicule. Il se parachute, il franchit une porte standard, il monte un escalier ordinaire et il manipule les objets normalisés déjà en dotation.
| Dimensions | 180 cm tall, 65 cm across the shoulders, 95 kg |
|---|---|
| Dimensions | 180 cm de haut, 65 cm aux épaules, 95 kg |
| Mobility | Running at 20 km/h with a 15-minute sprint, walking at 5 to 8 km/h, 35° slopes, 40 cm obstacles, standard stairs |
| Mobilité | Course à 20 km/h avec sprint de 15 min, marche de 5 à 8 km/h, pentes à 35°, obstacles de 40 cm, escaliers standards |
| Endurance | 8 to 10 hours walking, 45-minute fast charge, battery swap in under 5 minutes |
| Autonomie | 8 à 10 h de marche, recharge rapide en 45 min, échange de batteries en moins de 5 min |
| Manipulation | 85 cm reach, 20 kg payload, ±2 mm accuracy, force control below half a newton |
| Manipulation | 85 cm de portée, 20 kg de charge, précision ±2 mm, contrôle d’effort sous le demi-newton |
| Environment | IP67, −25 °C to +50 °C, under 40 dB at 10 m in silent mode |
| Environnement | IP67, −25 °C à +50 °C, moins de 40 dB à 10 m en mode furtif |
| Target compliance | MIL-STD-810H, MIL-STD-461G, STANAG 4586 and 4677, EU AI Act, ISO 12100 |
| Conformité visée | MIL-STD-810H, MIL-STD-461G, STANAG 4586 et 4677, EU AI Act, ISO 12100 |
| Status | Prototype in development. Field-validated prototype targeted for 2029, qualified pre-series from 2030. |
| État | Prototype en développement. Prototype validé en conditions réelles visé pour 2029, pré-série qualifiée à partir de 2030. |
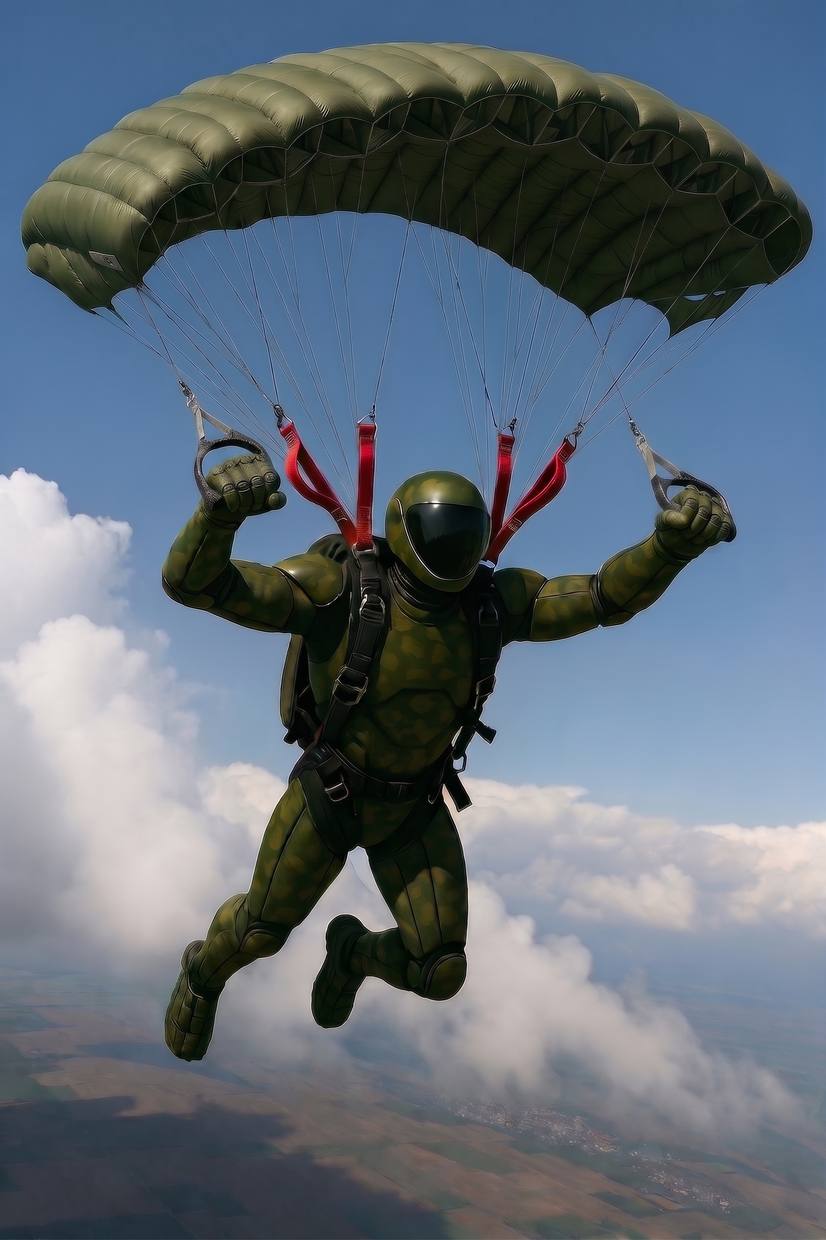
Air-droppableParachutable
Staying under 100 kg keeps the robot inside standard airborne insertion methods, so it arrives with the unit rather than behind it.Rester sous les 100 kg maintient le robot dans les modes d’insertion aéroportée standards : il arrive avec l’unité, pas derrière elle.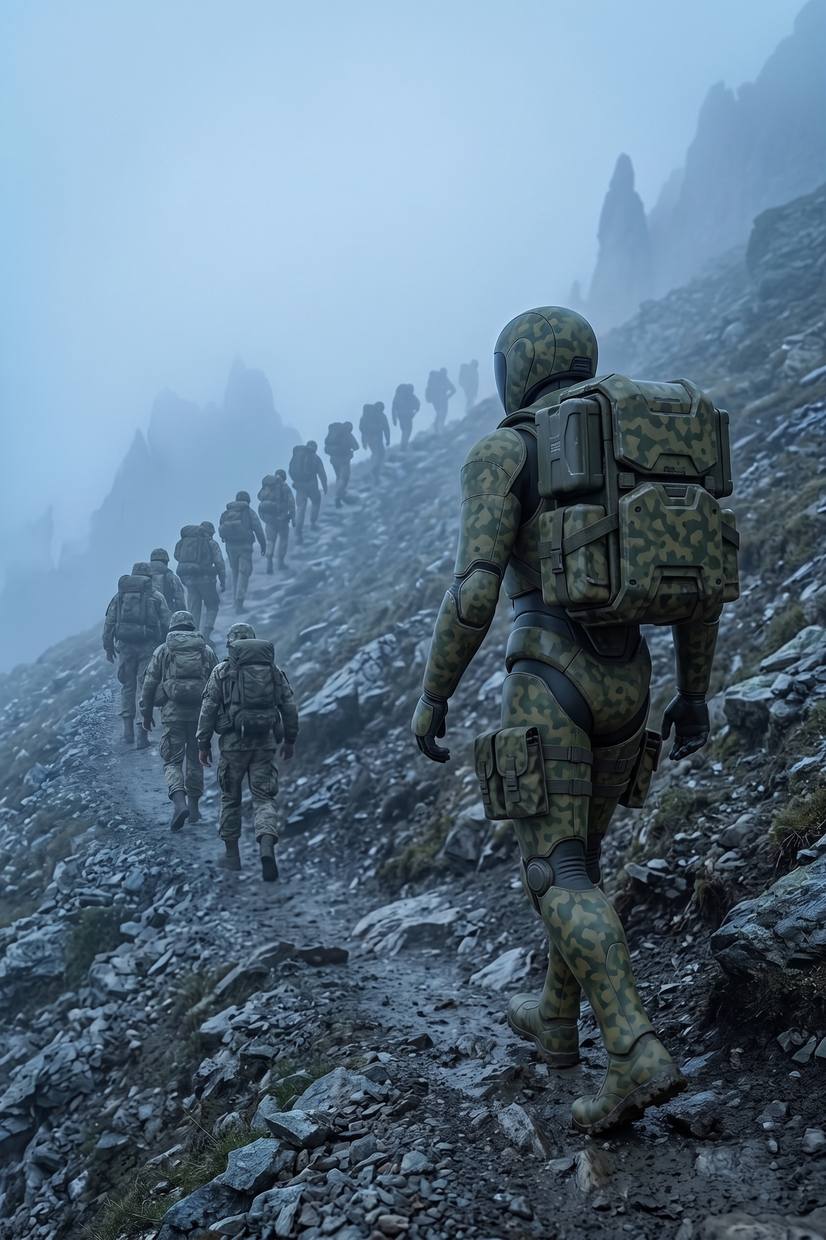
Carries the weightIl porte la charge
Ammunition, water, batteries, casualty equipment. Twenty kilos taken off the section, over ground no vehicle can follow.Munitions, eau, batteries, matériel de secours. Vingt kilos retirés au groupe, sur un terrain où aucun véhicule ne suit.Architecture
Four chains, every one of them redundant.Quatre chaînes, toutes redondées.
PerceptionPerception
Failure detected in under 100 msDéfaillance détectée en moins de 100 msA 128-channel LiDAR covering 360° out to 120 m, six RGB cameras, two thermal cameras, a tactical inertial unit and anti-jam military GNSS. Critical sensors are doubled and fused through an extended Kalman filter into a local probabilistic map refreshed at 10 Hz.Un LiDAR 128 canaux couvrant 360° jusqu’à 120 m, six caméras RGB, deux caméras thermiques, une centrale inertielle tactique et un GNSS militaire anti-brouillage. Les capteurs critiques sont doublés et fusionnés par filtrage de Kalman étendu dans une carte locale probabiliste rafraîchie à 10 Hz.
Cognition
550 TOPS on board, hot standby550 TOPS embarqués, redondance à chaudTwo computers run every critical function twice and cross-check the results. The NEUTRINO Ω tactical layer decides in under 30 ms, with rules-of-engagement compliance established by formal verification. Any lethal decision stays under human control, and that constraint is hard-coded.Deux calculateurs exécutent chaque fonction critique en double et confrontent les résultats. La couche tactique NEUTRINO Ω décide en moins de 30 ms, avec une conformité aux règles d’engagement établie par vérification formelle. Toute décision létale reste sous contrôle humain, contrainte codée en dur.
ActuationActionnement
Hybrid hydraulic and electricHybride hydraulique et électriqueLegs need torque peaks that only hydraulics deliver at acceptable mass: 300 Nm at the hip, 350 Nm at the knee, a 210 bar circuit with no combustion engine. Arms and ankles switch to electric drives with series elastic actuators, which return 12 to 18% of the energy spent walking.Les jambes exigent des pics de couple que seule l’hydraulique délivre à masse acceptable : 300 Nm à la hanche, 350 Nm au genou, circuit à 210 bar sans moteur thermique. Les bras et les chevilles passent à l’électrique avec actionneurs série élastiques, qui restituent 12 à 18 % de l’énergie dépensée à la marche.
Power and linksÉnergie et liaisons
200 kW transients absorbedPics de 200 kW absorbésA 10 kWh battery paired with supercapacitors to soak up impacts and accelerations. Tactical radio out to 30 km, satellite backup, mesh networking, AES-256-GCM encryption and frequency hopping at 1,000 hops per second. Under jamming the robot continues its current mission and accepts no unauthenticated order.Une batterie de 10 kWh associée à des supercondensateurs pour encaisser impacts et relances. Radio tactique jusqu’à 30 km, secours satellite, réseau maillé, chiffrement AES-256-GCM et saut de fréquence à 1 000 sauts par seconde. Sous brouillage, le robot poursuit sa mission en cours et n’accepte aucun ordre non authentifié.
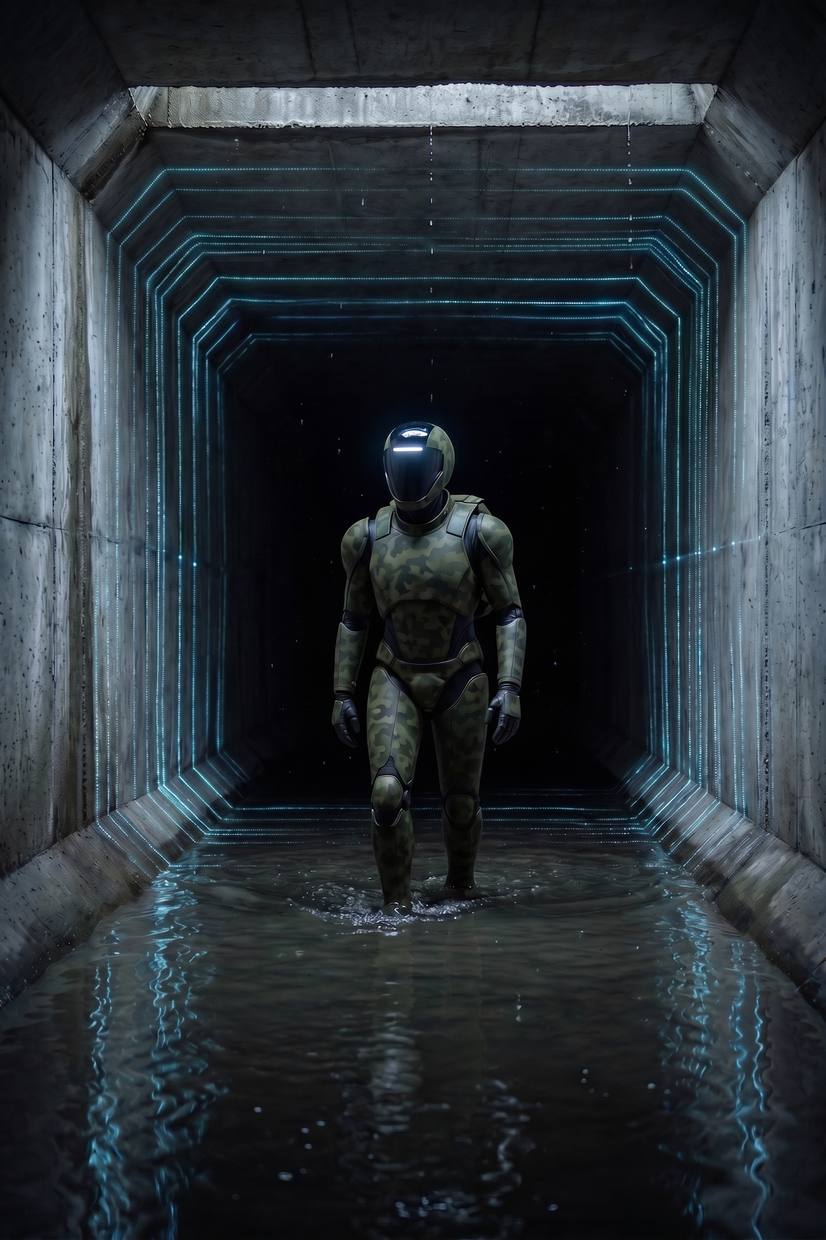
Degraded environmentsEnvironnements dégradés
No sky, no satellites, no signal.Pas de ciel, pas de satellites, pas de signal.
Underground, inside structures and under jamming, navigation falls back to pure LiDAR and visual-inertial SLAM. Lose the link and the robot keeps mapping, finishes the task in hand and returns to its last rally point on its own.Sous terre, à l’intérieur des structures et sous brouillage, la navigation bascule sur le LiDAR seul et le SLAM visuel-inertiel. Si la liaison tombe, le robot continue de cartographier, termine la tâche en cours et rejoint seul son dernier point de ralliement.
ControlContrôle
Three nested loops to hold 20 km/h.Trois boucles imbriquées pour tenir 20 km/h.
The robot is modelled as a floating multi-body system with 18 actuated degrees of freedom. The planner commits to footholds ahead of time, torque distribution is recomputed continuously, and the local loops close the servo at the millisecond.Le robot est modélisé comme un système multi-corps flottant à 18 degrés de liberté actionnés. Le planificateur choisit les appuis à l’avance, la répartition des couples est recalculée en continu et les boucles locales ferment l’asservissement à la milliseconde.
Every software increment clears four stages before it touches the field: large-scale simulation, a digital twin calibrated against real test data, a hardware-in-the-loop bench, then an instrumented run on the robot itself.Chaque incrément logiciel franchit quatre étages avant le terrain : simulation massive, jumeau numérique recalé sur les données d’essai réelles, banc hardware-in-the-loop, puis essai instrumenté sur le robot.
| Centroidal MPC | 120 Hz, centre-of-mass trajectory and foothold selection over a 1.5 s horizon |
|---|---|
| MPC centroïdal | 120 Hz, trajectoire du centre de masse et choix des appuis sur un horizon de 1,5 s |
| Whole-body control | 500 Hz, torque distribution across 18 axes under friction and no-slip constraints |
| Contrôle corps complet | 500 Hz, répartition des couples sur 18 axes sous contraintes de friction et de non-glissement |
| Torque servo | 1 kHz, pressure and flow on the hydraulic side, field-oriented control on the electric side |
| Asservissement en couple | 1 kHz, pression et débit côté hydraulique, contrôle vectoriel côté électrique |
| Supervision | 100 Hz, watchdogs, sensor consistency checks, degraded modes |
| Supervision | 100 Hz, chiens de garde, cohérence des capteurs, modes dégradés |
| Emergency stop | Four physical buttons and a radio cut-off under 50 ms. The robot settles onto its knees under control, never in free fall. |
| Arrêt d’urgence | Quatre boutons physiques et une coupure radio en moins de 50 ms. Le robot s’affaisse genoux fléchis, sous contrôle, jamais en chute libre. |
EmploymentEmploi
Where human exposure is no longer acceptable.Là où l’exposition humaine n’est plus acceptable.
Intended operational scenarios, shown here as concept renders. They define what the prototype is being built and tested against.Scénarios d’emploi envisagés, présentés ici sous forme de rendus conceptuels. Ils définissent ce contre quoi le prototype est construit et éprouvé.
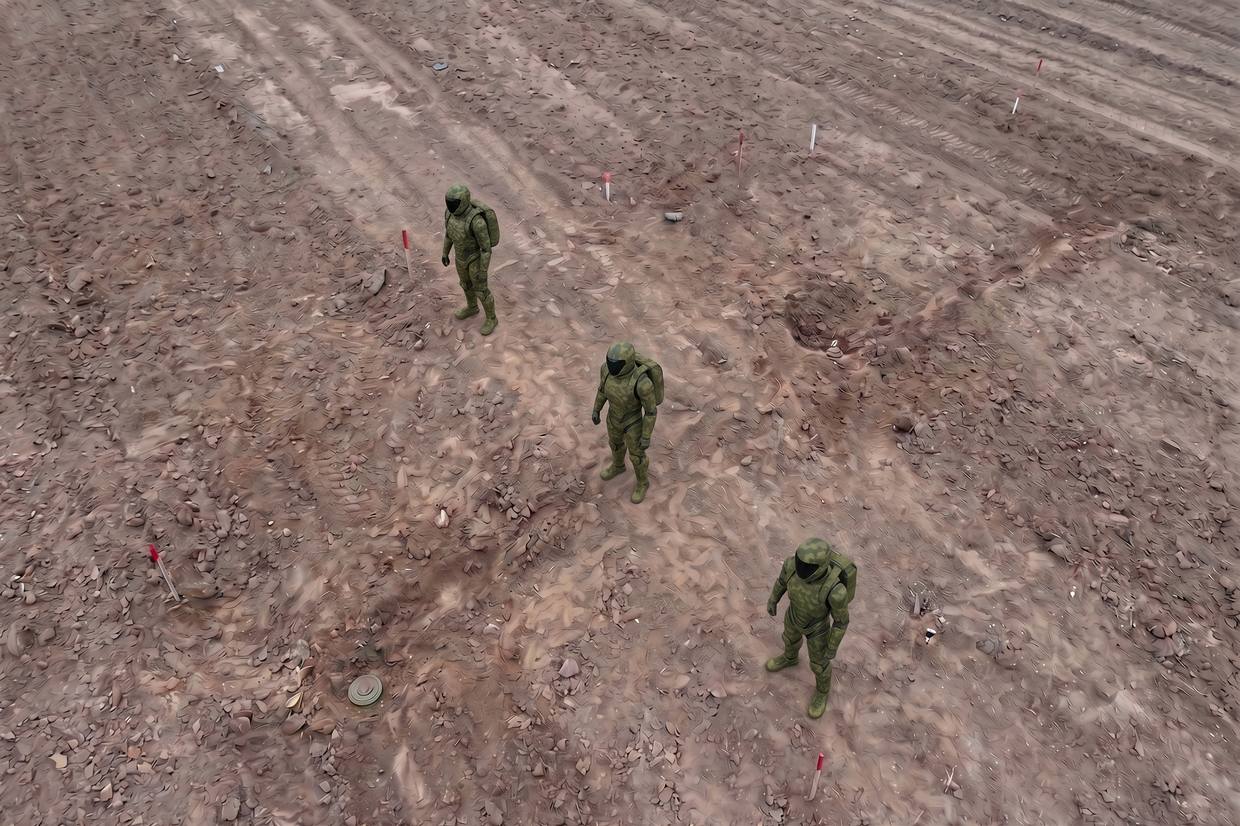
Humanitarian deminingDéminage humanitaire
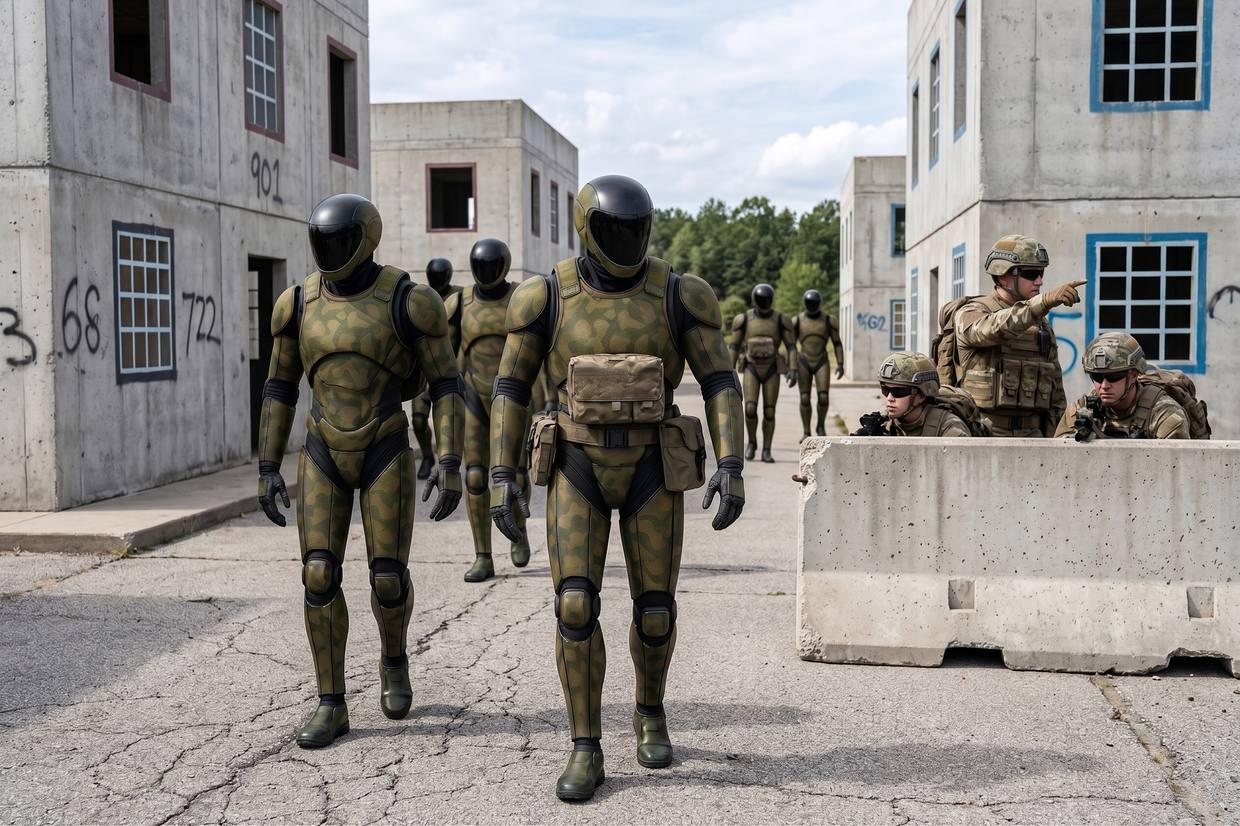
Urban reconnaissanceReconnaissance urbaine
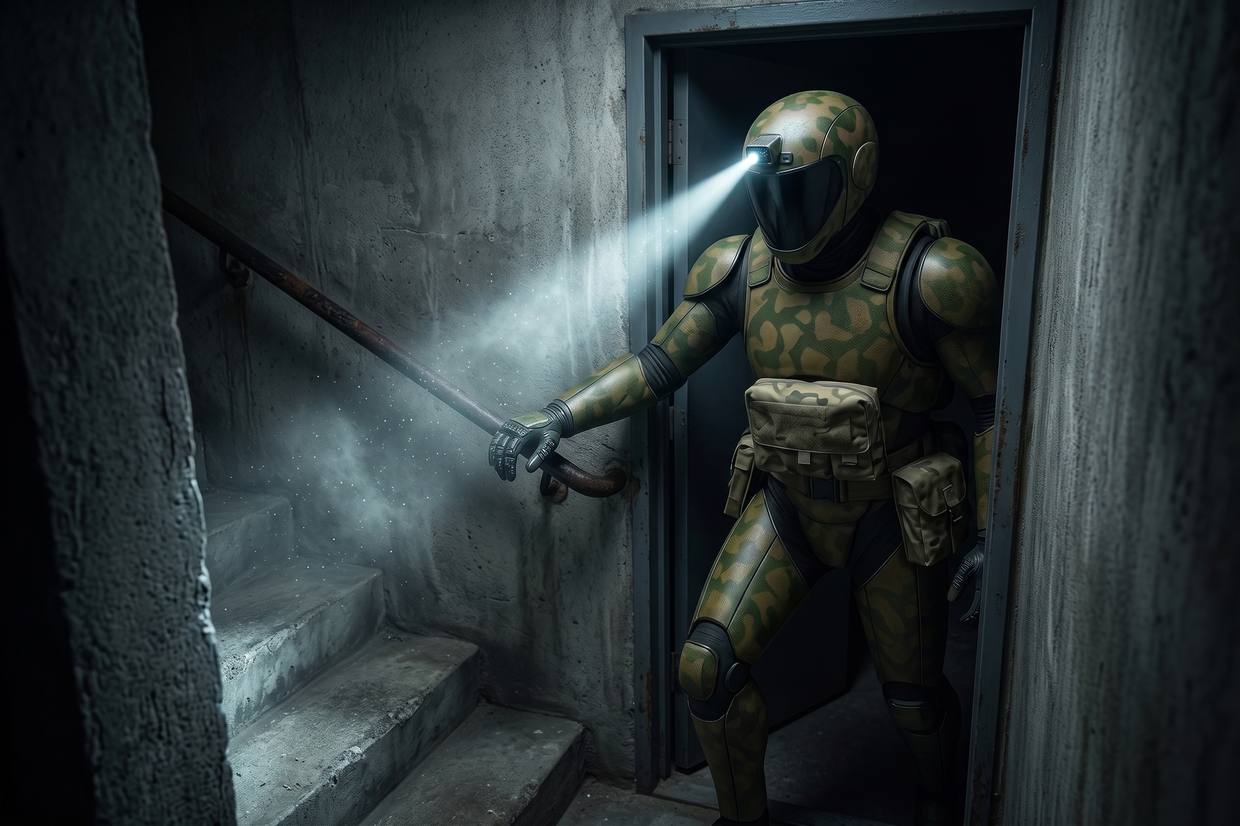
Structure entryPénétration de bâtiment
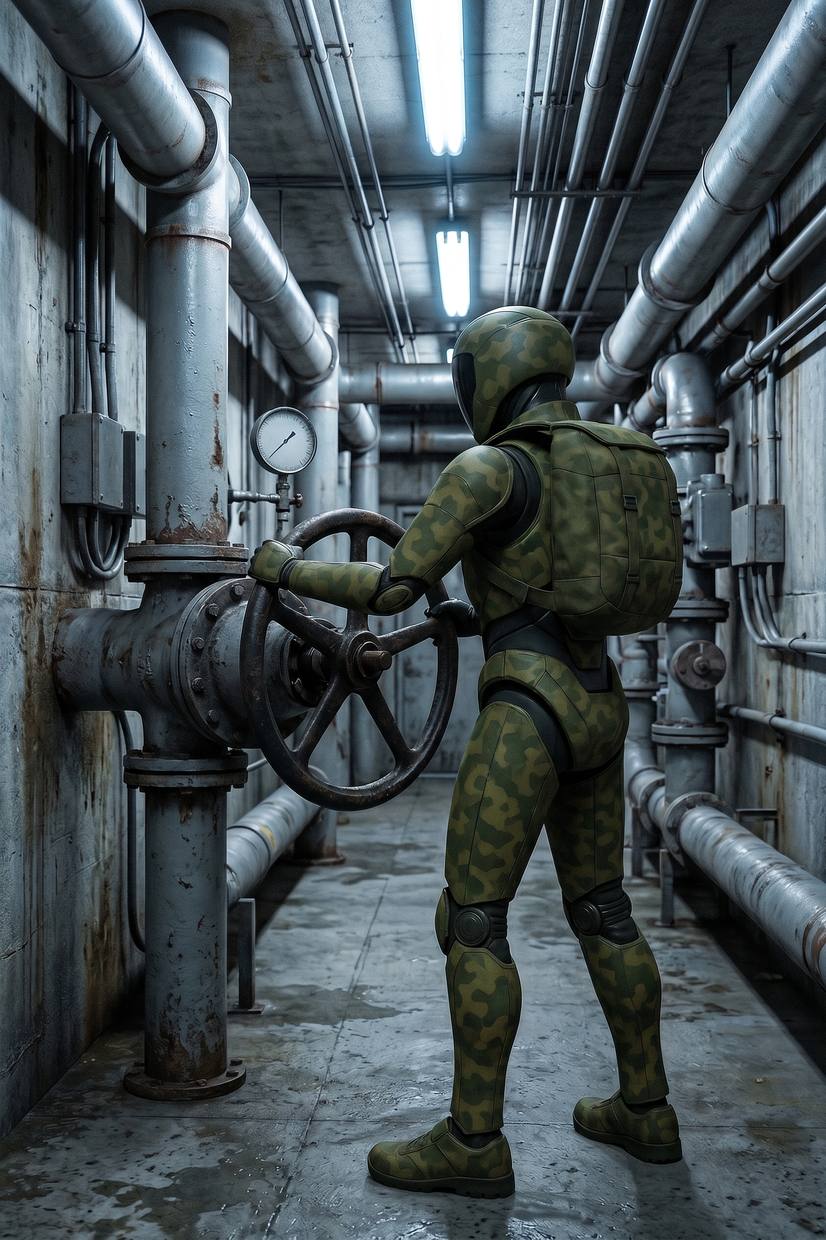
Contaminated and irradiated sitesSites contaminés et irradiés
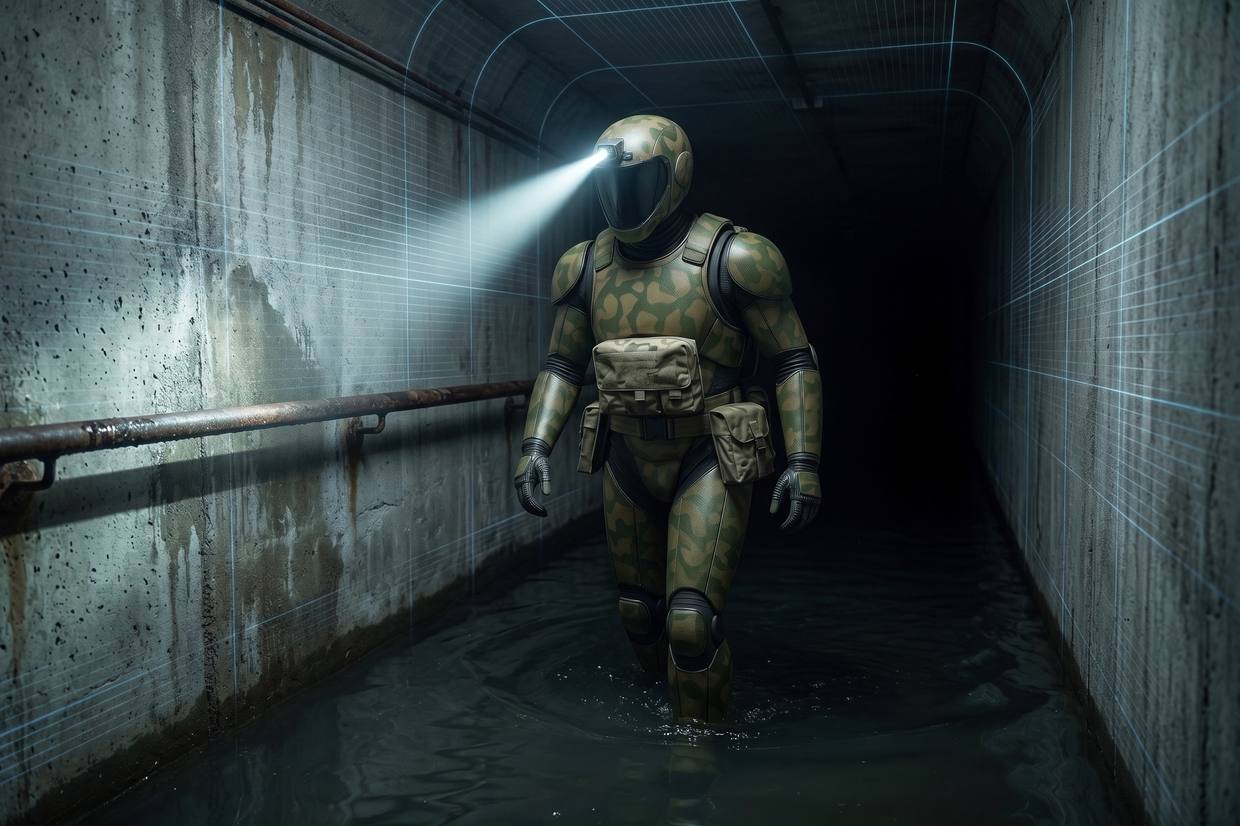
Underground surveyReconnaissance souterraine
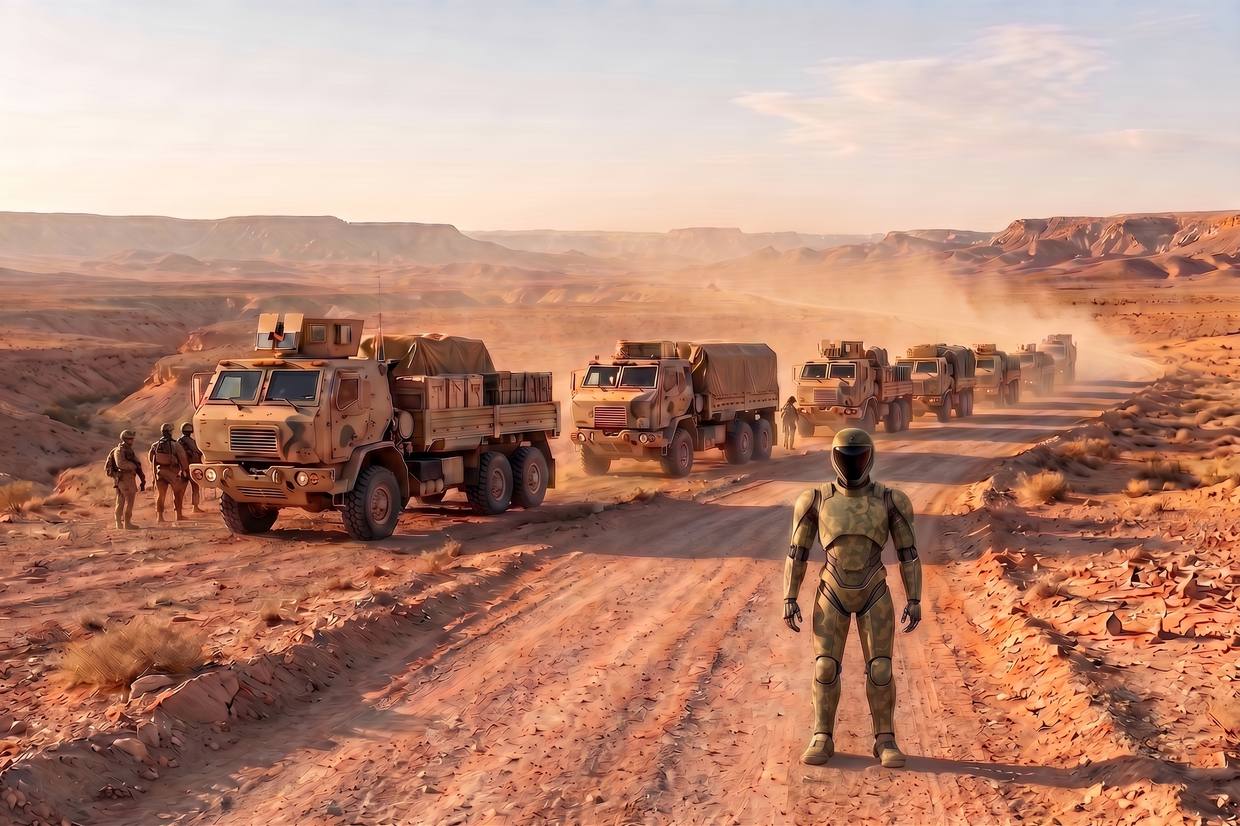
Convoy and route workConvois et ouverture d’itinéraire
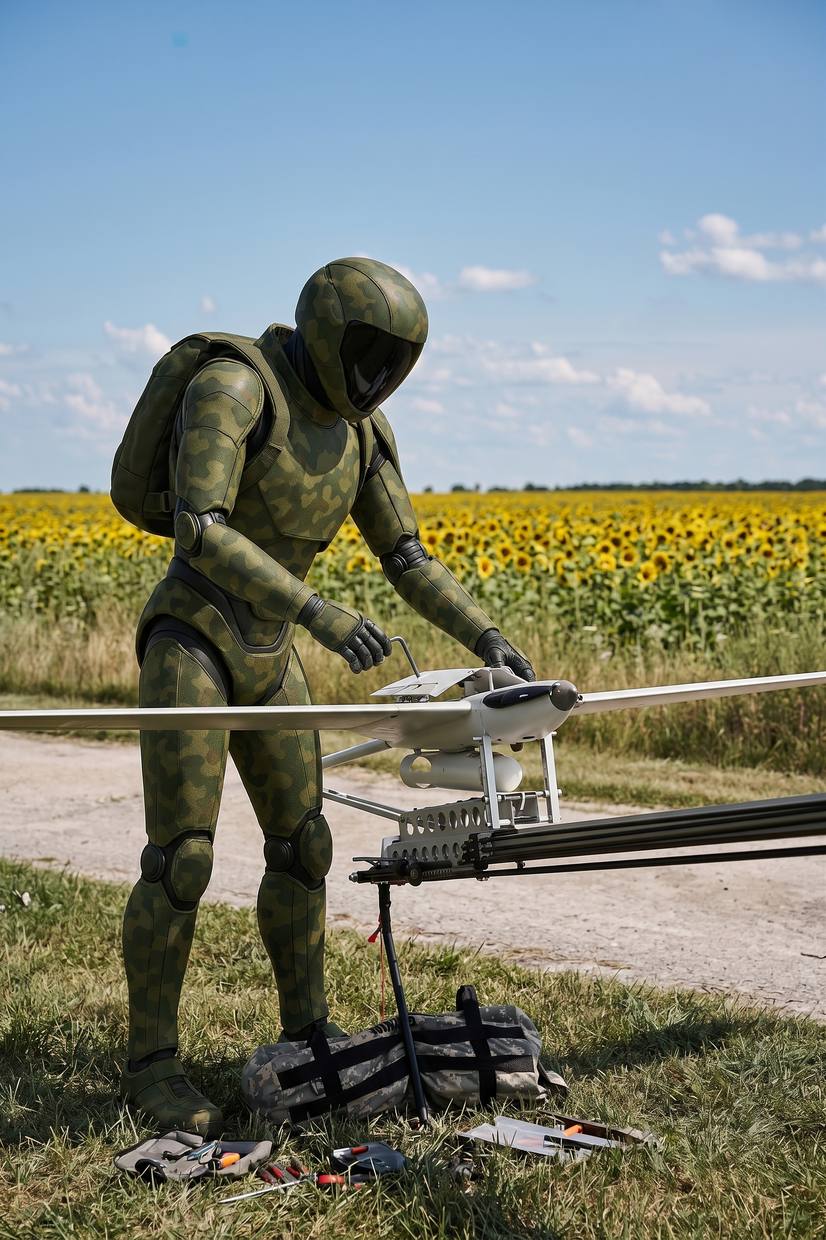
Unmanned systems supportSoutien aux systèmes sans pilote
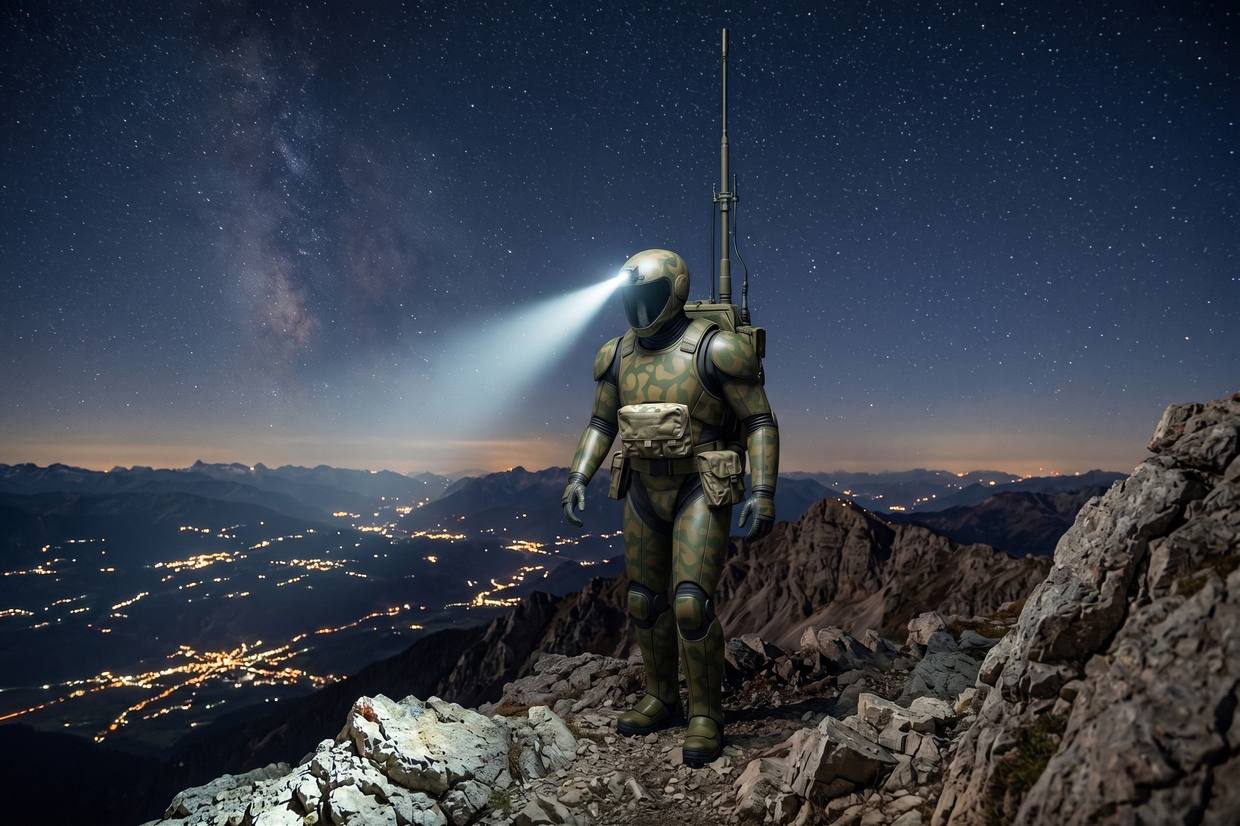
Relay and overwatchRelais et surveillance
These are simulations of intended employment, not footage of a delivered system. Any decision to open fire remains subject to human validation, a constraint written into the system's ethics layer and established by formal verification.Il s’agit de simulations d’emploi envisagé, pas de prises de vue d’un système livré. Toute décision d’ouverture du feu reste soumise à validation humaine, contrainte inscrite dans la couche éthique du système et établie par vérification formelle.
SovereigntySouveraineté
92% European content today, 100% targeted at Mk.III.92 % de valeur européenne aujourd’hui, 100 % visés au Mk.III.
Actuation, power, communications and modularity are entirely European or Swiss, and the software is proprietary. Compute and part of the first-generation sensor set remain American in origin, selected outside the ITAR perimeter, with a substitution path already under way.L’actionnement, l’énergie, les communications et la modularité sont intégralement européens ou suisses, et le logiciel est propriétaire. Le calcul et une partie des capteurs de première génération restent d’origine américaine, choisis hors périmètre ITAR, avec une trajectoire de substitution déjà engagée.
Embedded AI, control software and mission autonomy are developed inside the group rather than licensed in. The sourcing map and supplier names are shared with qualified counterparts under agreement.L’IA embarquée, le logiciel de contrôle et l’autonomie de mission sont développés dans le groupe et non sous licence. La cartographie des approvisionnements et les noms des fournisseurs sont communiqués aux interlocuteurs qualifiés sous accord.
Employment doctrineDoctrine d’emploi
Human control is mandatory for any lethal decision and is written into the system's ethics layer. An independent ethics committee oversees employment doctrine and compliance with the EU AI Act and international humanitarian law.Le contrôle humain est obligatoire pour toute décision létale et inscrit dans la couche éthique du système. Un comité d’éthique indépendant suit la doctrine d’emploi et la conformité à l’EU AI Act et au droit international humanitaire.
Where we areOù nous en sommes
The prototype is being built now.Le prototype est en cours de construction.
AIR ROBOTICS is a development-stage company and the AV-RX Mk.II is not a catalogue item. The programme is built on decreasing risk rather than increasing ambition: prove the mechanics before the intelligence, the intelligence before the weather, and the weather before the production line. The earliest stage is deliberately the least glamorous one.AIR ROBOTICS est une société en phase de développement et l’AV-RX Mk.II n’est pas un produit sur catalogue. Le programme repose sur une réduction progressive du risque plutôt que sur une montée en ambition : prouver la mécanique avant l’intelligence, l’intelligence avant les intempéries, et les intempéries avant la ligne de production. La première étape est délibérément la moins spectaculaire.
The method comes from aerospace rather than from software. Nothing is industrialised until it has been shown to be certifiable and, just as important, acceptable to the people who will work alongside it.La méthode vient de l’aéronautique et non du logiciel. Rien n’est industrialisé avant d’avoir été démontré certifiable et, tout aussi important, acceptable par ceux qui travailleront à ses côtés.
Teleoperated demonstrator running the full movement envelope.
Démonstrateur télé-opéré parcourant tout le domaine de mouvement.
Autonomous prototype in a controlled environment.
Prototype autonome en environnement contrôlé.
Field-validated prototype, the reference availability date.
Prototype validé en conditions réelles, date de disponibilité de référence.
Qualified pre-series delivered to pilot users.
Pré-série qualifiée livrée aux utilisateurs pilotes.
Dates are targets counted from programme launch and assume the funding and recruitment milestones are met. The 2029 date is the one we hold ourselves to.Ces dates sont des objectifs comptés à partir du lancement du programme et supposent que les jalons de financement et de recrutement soient tenus. C’est sur 2029 que nous nous engageons.
-
STAGE 01ÉTAPE 01
Building the prototypeConstruction du prototype
From CAD to hardwareDe la CAO au matérielThe first machine is built for real: aerospace-alloy structure, hydraulic actuation in the legs, electric drives with series elastic actuators at the arms and ankles, the hydraulic circuit, the harness and the joint-level instrumentation. Every joint is characterised on a torque bench before it goes into the assembly, so that a limb that behaves oddly later is a known quantity rather than a mystery.La première machine est construite pour de bon : structure en alliage aéronautique, actionnement hydraulique dans les jambes, entraînements électriques à actionneurs série élastiques aux bras et aux chevilles, circuit hydraulique, faisceau et instrumentation au niveau de chaque articulation. Chaque articulation est caractérisée sur banc de couple avant d’entrer dans l’assemblage, pour qu’un membre au comportement étrange soit plus tard une donnée connue et non une énigme.
- StructureMachined and assembled frame, joint housings and mounting interfaces, built to the dimensions the design has committed to.
- StructureChâssis usiné et assemblé, carters d’articulation et interfaces de montage, aux dimensions arrêtées par la conception.
- ActuationHip, knee, ankle, shoulder and elbow units each qualified on the bench for torque, speed and thermal behaviour before integration.
- ActionnementHanche, genou, cheville, épaule et coude, chaque ensemble qualifié sur banc en couple, en vitesse et en comportement thermique avant intégration.
- IntegrationHydraulic circuit, wiring harness, power distribution and joint encoders, with leak and continuity testing at each stage.
- IntégrationCircuit hydraulique, faisceau électrique, distribution de puissance et codeurs d’articulation, avec essais d’étanchéité et de continuité à chaque étape.
- Ergonomics on the real machineDoorway clearance, two-man lifting points, compartment access heights and marking legibility, checked with serving personnel on the actual hardware.
- Ergonomie sur la machine réellePassage de porte, points de levage à deux, hauteurs d’accès aux compartiments et lisibilité des marquages, vérifiés avec des militaires en activité sur le matériel lui-même.
- Exit conditionA powered machine that holds its own weight, moves every joint under command, and is instrumented well enough to be trusted as a test article.
- Condition de sortieUne machine sous puissance qui tient son propre poids, actionne chaque articulation sur commande, et reste assez instrumentée pour servir de matériel d’essai fiable.
-
STAGE 02ÉTAPE 02
Motion-capture teleoperationTélé-opération par capture de mouvement
Human in the loopHumain dans la boucleThe robot is driven by a human athlete in a motion-capture suit, tracked by an infrared camera array at 120 Hz and replicated on the machine in under 100 ms. The human is the brain, the robot is the body. Kinematics and actuation get proven with no AI anywhere in the loop, which isolates hardware failures from software ones. Budget goes into actuation and structure; perception stays deliberately minimal, because nothing on the robot is doing the thinking yet.Le robot est piloté par un athlète en combinaison de capture de mouvement, suivi par un réseau de caméras infrarouges à 120 Hz et répliqué sur la machine en moins de 100 ms. L’humain est le cerveau, le robot est le corps. La cinématique et l’actionnement sont validés sans aucune IA dans la boucle, ce qui isole les défaillances matérielles des défaillances logicielles. L’effort porte sur l’actionnement et la structure ; la perception reste volontairement minimale, puisque rien à bord ne réfléchit encore.
- ProgressionStanding balance, then slow walking, fast walking, running, manipulation, then an integrated obstacle course.
- ProgressionÉquilibre sur place, puis marche lente, marche rapide, course, manipulation, enfin un parcours d’obstacles intégré.
- Operator profileA gymnast, dancer or stunt performer, matched to the robot's dimensions and trained on tactical movement.
- Profil de l’opérateurGymnaste, danseur ou cascadeur, aux dimensions accordées à celles du robot et formé aux gestes tactiques.
- Recorded per frameSeventeen body points, eighteen joint positions, velocities and torques, ground reaction from four foot sensors, synchronised video.
- Enregistré à chaque imageDix-sept points du corps, dix-huit positions articulaires, vitesses et couples, efforts au sol de quatre capteurs de pied, vidéos synchronisées.
- OutputAn annotated dataset of human movement that becomes the training set for the autonomy stack.
- RésultatUn jeu de données annoté de mouvements humains, qui devient l’ensemble d’entraînement de la pile d’autonomie.
-
STAGE 03ÉTAPE 03
Indoor autonomyAutonomie en laboratoire
Controlled environmentEnvironnement contrôléControl moves off the operator and onto the machine. The autonomy stack is trained by reinforcement learning with an imitation warm start on the recorded dataset, then validated in an instrumented hall rather than in simulation alone. Hardware steps up to the full sensor set, redundant compute, the production battery and the real gripper.Le contrôle quitte l’opérateur pour passer à la machine. La pile d’autonomie est entraînée par apprentissage par renforcement avec amorçage par imitation sur le jeu de données enregistré, puis validée dans une halle instrumentée plutôt qu’en simulation seule. Le matériel monte au jeu de capteurs complet, au calcul redondant, à la batterie de série et au préhenseur définitif.
- Test hallFlat running ground, three flights of stairs, obstacle blocks, a manipulation bench and a slalom course, under fixed cameras and floor pressure mats.
- Halle d’essaiSol plat pour la course, trois volées d’escalier, blocs d’obstacles, établi de manipulation et parcours de slalom, sous caméras fixes et tapis de pression.
- LocomotionWaypoint navigation, static obstacle avoidance, stairs up and down, and speed held on the flat.
- LocomotionNavigation par points de passage, évitement d’obstacles statiques, escaliers en montée et en descente, vitesse tenue sur le plat.
- ManipulationGrasping a varied set of objects, including standard-issue items.
- ManipulationPréhension d’objets variés, dont des matériels en dotation.
- Teammate scenarioFollow a section in formation, carry 20 kg up three floors, place it at a defensive position and return unaided.
- Scénario coéquipierSuivre un groupe en formation, monter 20 kg sur trois étages, les déposer en position défensive et revenir seul.
- Measured onFormation spacing, zero collisions with people or obstacles, delivery time, and usefulness as rated by the soldiers involved.
- CritèresTenue de la formation, zéro collision avec les personnes ou les obstacles, temps de livraison, et utilité perçue par les soldats concernés.
-
STAGE 04ÉTAPE 04
Field validationValidation en conditions réelles
Uncontrolled environmentEnvironnement non contrôléThe hardest stage, and the one that decides everything downstream. The machine is ruggedised and then taken out of the laboratory into weather, terrain and dirt it cannot be protected from. Sealing goes to IP67, the operating envelope to −25 °C and +50 °C, the structure to aerospace alloy, the connectors to mil-spec, and a hardware watchdog is added underneath the software.L’étape la plus dure, celle qui conditionne tout le reste. La machine est durcie puis sortie du laboratoire pour affronter un temps, un terrain et une saleté dont on ne peut pas la protéger. L’étanchéité passe à IP67, l’enveloppe d’emploi à −25 °C et +50 °C, la structure à un alliage aéronautique, la connectique au standard militaire, et un chien de garde matériel est ajouté sous le logiciel.
- EnvironmentsMediterranean heat and dust, an urban training area, mountain slopes and scree, extreme cold and deep snow, coastal sand and salt air.
- MilieuxChaleur et poussière méditerranéennes, zone d’entraînement urbain, pentes et pierriers de montagne, froid extrême et neige épaisse, sable et air salin du littoral.
- Load carriage20 kg over 5 km of mixed terrain with 200 m of climb, arriving with the load intact and reserve in the battery.
- Portage20 kg sur 5 km de terrain mixte avec 200 m de dénivelé, charge intacte à l’arrivée et réserve dans la batterie.
- Reconnaissance500 m of autonomous progression ahead of a section inside a building, streaming video and 3D mapping back in real time.
- Reconnaissance500 m de progression autonome en tête d’un groupe à l’intérieur d’un bâtiment, avec vidéo et cartographie 3D renvoyées en temps réel.
- Cold enduranceA 2 km perimeter patrol held for four hours at −20 °C, including static observation.
- Endurance au froidPatrouille de 2 km tenue quatre heures à −20 °C, observation statique comprise.
- MIL-STD methodsHeat, cold, driving rain, sand and dust, vibration and shock, run with an accredited laboratory.
- Essais MIL-STDChaleur, froid, pluie battante, sable et poussière, vibrations et chocs, conduits avec un laboratoire accrédité.
- Beta usePartner infantry sections using the robot daily, with structured feedback and a weekly fix and over-the-air firmware cycle.
- Emploi en version bêtaDes groupes d’infanterie partenaires utilisent le robot au quotidien, avec retours structurés et cycle hebdomadaire de correctifs et de mises à jour à distance.
-
STAGE 05ÉTAPE 05
Qualified pre-seriesPré-série qualifiée
Production readinessAptitude à la productionOnly once the machine has survived the field does it go anywhere near a production line. A qualified pre-series is built on a stationed assembly line, certification is completed rather than started, and the first operators and maintainers are trained. Reliability, not speed, is the qualifying metric.Ce n’est qu’après avoir survécu au terrain que la machine s’approche d’une ligne de production. Une pré-série qualifiée est assemblée sur une ligne à postes, la certification est achevée plutôt qu’entamée, et les premiers opérateurs et mainteneurs sont formés. Le critère de qualification est la fiabilité, pas la cadence.
- Assembly stationsChassis, actuation integration on a torque bench, wiring harness, hydraulic circuit and leak test, sensor calibration, battery and BMS, final assembly, then a 72-hour quality run.
- Postes d’assemblageChâssis, intégration de l’actionnement sur banc de couple, faisceau électrique, circuit hydraulique et test d’étanchéité, calibration des capteurs, batterie et BMS, assemblage final, puis 72 heures de contrôle qualité.
- CertificationThe full MIL-STD environmental and electromagnetic programme, plus machinery safety and functional safety standards.
- CertificationLe programme MIL-STD complet, environnemental et électromagnétique, plus les normes de sécurité machine et de sécurité fonctionnelle.
- ReliabilityAn MTBF target validated by accelerated ageing rather than claimed.
- FiabilitéUn objectif de MTBF validé par vieillissement accéléré, et non simplement annoncé.
- SupportOperator and two-level maintenance training, embedded field engineering at handover, and a co-built improvement roadmap with users.
- SoutienFormation des opérateurs et de la maintenance à deux niveaux, ingénierie de terrain intégrée à la mise en service, et feuille de route d’amélioration construite avec les utilisateurs.
JoiningNous rejoindre
The people the prototype needs.Les profils dont le prototype a besoin.
A walking machine fails at the seams between disciplines, so we hire people who are willing to work either side of their own. These are the profiles that move the prototype forward.Une machine qui marche cède aux jointures entre disciplines. Nous recrutons donc des gens prêts à travailler de part et d’autre de la leur. Voici les profils qui font avancer le prototype.
Legged robotics leadResponsable robotique à pattes
Owns dynamic locomotion end to end, from contact planning to what the machine actually does on scree. We are looking for someone who has taken a bipedal or quadruped robot outdoors, not only through simulation.Porte la locomotion dynamique de bout en bout, de la planification des appuis à ce que la machine fait réellement sur un pierrier. Nous cherchons quelqu’un qui a sorti un bipède ou un quadrupède en extérieur, pas seulement en simulation.
Whole-body control, centroidal MPC, contact scheduling, floating-base dynamics. C++17, ROS 2, Pinocchio or Drake, MuJoCo or Isaac. Doctorate or equivalent industrial track record.Contrôle corps complet, MPC centroïdal, ordonnancement des contacts, dynamique à base flottante. C++17, ROS 2, Pinocchio ou Drake, MuJoCo ou Isaac. Doctorat ou parcours industriel équivalent.Mechanical design engineerIngénieur conception mécanique
Designs the structure and the joint architecture, then follows them through machining and assembly. The constraint is brutal and simple: under 100 kg, with impact loads at every stride.Conçoit la structure et l’architecture des articulations, puis les suit jusqu’à l’usinage et au montage. La contrainte est brutale et simple : moins de 100 kg, avec des charges d’impact à chaque foulée.
CATIA or SolidWorks, finite element and fatigue analysis, tolerance stack-up, aluminium and titanium machining, design for manufacture. Aerospace, motorsport or robotics background.CATIA ou SolidWorks, calcul par éléments finis et tenue en fatigue, chaînes de cotes, usinage aluminium et titane, conception pour la fabrication. Parcours aéronautique, sport automobile ou robotique.Actuation engineerIngénieur actionnement
Sizes, builds and characterises every joint, hydraulic in the legs and electric at the arms and ankles, and owns the torque bench where each one is qualified before assembly.Dimensionne, réalise et caractérise chaque articulation, hydraulique dans les jambes et électrique aux bras et aux chevilles, et tient le banc de couple où chacune est qualifiée avant assemblage.
Servo valves, variable-displacement pumps, 210 bar circuits, PMSM and BLDC sizing, field-oriented control, series elastic actuator stiffness design, dynamometer benches, thermal derating.Servovalves, pompes à cylindrée variable, circuits 210 bar, dimensionnement PMSM et BLDC, commande vectorielle, raideur des actionneurs série élastiques, bancs dynamométriques, déclassement thermique.Control engineerIngénieur commande
Writes the loops that must never miss a deadline: 120 Hz planning, 500 Hz whole-body distribution, 1 kHz torque servo, and the degraded modes underneath them.Écrit les boucles qui n’ont pas le droit de manquer une échéance : planification à 120 Hz, répartition corps complet à 500 Hz, asservissement en couple à 1 kHz, et les modes dégradés en dessous.
Quadratic programming and solvers such as OSQP or qpOASES, state estimation and Kalman filtering, C++17, real-time Linux with PREEMPT_RT, EtherCAT or CAN FD, deterministic scheduling.Programmation quadratique et solveurs type OSQP ou qpOASES, estimation d’état et filtrage de Kalman, C++17, Linux temps réel PREEMPT_RT, EtherCAT ou CAN FD, ordonnancement déterministe.Perception and learning engineerIngénieur perception et apprentissage
Builds the local map the robot walks on and the learned policies that use it, then does the unglamorous work of making both survive the move from simulation to hardware.Construit la carte locale sur laquelle le robot marche et les politiques apprises qui l’exploitent, puis fait le travail ingrat qui permet aux deux de survivre au passage de la simulation au matériel.
Visual-inertial and LiDAR SLAM, sensor fusion, traversability estimation, PyTorch, PPO or SAC, domain randomisation, CUDA and TensorRT on Jetson-class targets.SLAM visuel-inertiel et LiDAR, fusion de capteurs, estimation de franchissabilité, PyTorch, PPO ou SAC, randomisation de domaine, CUDA et TensorRT sur cibles de classe Jetson.Embedded software and safety engineerIngénieur logiciel embarqué et sécurité
Owns the partitioned architecture that keeps a compromised radio away from the motor controllers, and the analysis that proves the machine fails in a controlled direction.Porte l’architecture partitionnée qui tient une radio compromise à distance des contrôleurs moteurs, et l’analyse qui démontre que la machine défaille dans une direction maîtrisée.
C and C++, RTOS or Zephyr, partitioning and hypervisors, ISO 13849 and IEC 61508, FMEA and fault trees, secure boot with TPM 2.0, signed images, watchdog design.C et C++, RTOS ou Zephyr, partitionnement et hyperviseurs, ISO 13849 et CEI 61508, AMDEC et arbres de défaillance, démarrage sécurisé avec TPM 2.0, images signées, conception des chiens de garde.Power and thermal engineerIngénieur énergie et thermique
Delivers eight hours of endurance and 200 kW transients from the same architecture, and gets the heat out through a single liquid loop shared with the hydraulics.Tire huit heures d’autonomie et des transitoires de 200 kW de la même architecture, et évacue la chaleur par une boucle liquide unique partagée avec l’hydraulique.
Li-ion pack design and battery management, supercapacitor buffering, DC-DC conversion, thermal simulation and CFD, liquid cooling loops, EMC design, IP67 sealing.Conception de packs lithium-ion et gestion de batterie, tampon par supercondensateurs, conversion continu-continu, simulation thermique et CFD, boucles de refroidissement liquide, conception CEM, étanchéité IP67.Test and qualification engineerIngénieur essais et qualification
Instruments the machine, runs the benches and owns the compliance matrix, so that certification is a paperwork exercise rather than a discovery.Instrumente la machine, conduit les bancs et tient la matrice de conformité, pour que la certification soit un exercice documentaire et non une découverte.
MIL-STD-810H and MIL-STD-461G methods, hardware-in-the-loop benches, data acquisition, strain gauges and telemetry, test plan writing, statistical analysis of trial results.Méthodes MIL-STD-810H et MIL-STD-461G, bancs hardware-in-the-loop, acquisition de données, jauges de contrainte et télémesure, rédaction de plans d’essai, analyse statistique des résultats.Motion-capture operatorOpérateur de capture de mouvement
Becomes the machine's nervous system during the first phase, driving the robot through its whole movement envelope and generating the dataset the autonomy stack is trained on.Devient le système nerveux de la machine pendant la première phase, en promenant le robot dans tout son domaine de mouvement et en produisant le jeu de données qui entraîne la pile d’autonomie.
Gymnastics, dance or stunt background with exceptional body control, 175 to 185 cm, comfortable in an optical capture suit for long sessions. Tactical movement training provided.Parcours gymnastique, danse ou cascade avec un contrôle corporel exceptionnel, 175 à 185 cm, à l’aise en combinaison de capture optique sur de longues séances. Formation aux gestes tactiques assurée.Military programmes leadResponsable programmes militaires
Turns operational need into requirements engineers can build against, plans the trials with end users, and navigates the procurement pathways that decide whether good hardware reaches a unit.Traduit le besoin opérationnel en exigences sur lesquelles des ingénieurs peuvent travailler, prépare les essais avec les utilisateurs et navigue dans les voies d’acquisition dont dépend l’arrivée d’un bon matériel dans une unité.
Requirements capture and doctrine writing, STANAG interoperability, European and NATO procurement processes, trials management. Service or defence procurement background, eligible for security clearance.Recueil du besoin et rédaction de doctrine, interopérabilité STANAG, processus d’acquisition européens et OTAN, conduite des essais. Parcours en unité ou en acquisition de défense, éligible à une habilitation.Intellectual property and export control leadResponsable propriété intellectuelle et contrôle à l’export
Drafts patents next to the engineers rather than after them, and keeps the programme on the right side of dual-use rules in every jurisdiction we sell into.Rédige les brevets aux côtés des ingénieurs plutôt qu’après eux, et maintient le programme du bon côté des règles sur les biens à double usage dans chaque juridiction visée.
Patent drafting and prosecution before INPI and the EPO, PCT and national phases, freedom-to-operate searches, dual-use classification under EU regulation 2021/821, ITAR and EAR awareness.Rédaction et suivi de brevets devant l’INPI et l’OEB, PCT et phases nationales, recherches de liberté d’exploitation, classement double usage au titre du règlement UE 2021/821, connaissance ITAR et EAR.Speculative applicationsCandidatures spontanées
If your discipline is not listed and you can explain in three lines why the programme is worse off without you, write to us anyway. Several of the roles above did not exist until someone argued for them.Si votre discipline ne figure pas dans cette liste et que vous pouvez expliquer en trois lignes ce que le programme perd sans vous, écrivez-nous quand même. Plusieurs des postes ci-dessus n’existaient pas avant que quelqu’un les défende.
Tell us what you have built, what broke, and what you did about it.Dites-nous ce que vous avez construit, ce qui a cassé, et ce que vous en avez fait.How to applyComment postuler
Applications go to recrutement@air-robotics.fr and are read by the engineers you would be working with. Send a CV, three lines on why this programme rather than another one, and a link to something you have built. Papers, repositories, test reports and photographs of hardware all count. Tell us your notice period and your working languages.Les candidatures sont à adresser à recrutement@air-robotics.fr et sont lues par les ingénieurs avec qui vous travailleriez. Envoyez un CV, trois lignes sur les raisons de ce programme plutôt qu’un autre, et un lien vers quelque chose que vous avez construit. Publications, dépôts de code, rapports d’essai et photos de matériel comptent autant. Indiquez votre préavis et vos langues de travail.
Doctoral and post-doctoral positions are set up with partner laboratories. Internships are on real subtasks of the programme, supervised by the engineer who owns the subsystem.Les postes doctoraux et postdoctoraux sont montés avec des laboratoires partenaires. Les stages portent sur de vraies sous-tâches du programme, encadrés par l’ingénieur responsable du sous-ensemble.
Send an applicationEnvoyer une candidatureWho we recruit.Qui nous recrutons.
Doctorates where the problem is still open, engineers where it is a matter of execution, and skilled trades because a prototype is welded, wired and bled by hand before it is ever driven by software.Des docteurs là où le problème reste ouvert, des ingénieurs là où il relève de l’exécution, et des compagnons parce qu’un prototype est soudé, câblé et purgé à la main bien avant d’être piloté par du logiciel.
DOCTORATESDOCTORATS
- Legged locomotion and dynamic balance
- Locomotion à pattes et équilibre dynamique
- Computer vision and SLAM
- Vision par ordinateur et SLAM
- Reinforcement learning and sim-to-real transfer
- Apprentissage par renforcement et transfert simulation vers réel
- Structural materials and fatigue
- Matériaux de structure et tenue en fatigue
- Energy storage and thermal management
- Stockage d’énergie et gestion thermique
- Formal verification and software safety
- Vérification formelle et sûreté logicielle
ENGINEERSINGÉNIEURS
- Mechanical design and structures
- Conception mécanique et structures
- Hydraulics and servo valves
- Hydraulique et servovalves
- Electrical machines and power electronics
- Machines électriques et électronique de puissance
- Embedded electronics and real-time systems
- Électronique embarquée et systèmes temps réel
- Networks, radio and cybersecurity
- Réseaux, radio et cybersécurité
- Test, instrumentation and metrology
- Essais, instrumentation et métrologie
- Industrialisation and manufacturing methods
- Industrialisation et méthodes
TECHNICIANS AND TRADESTECHNICIENS ET COMPAGNONS
- Machining, fitting and assembly
- Usinage, ajustage et montage
- Hydraulic circuit build and leak testing
- Montage des circuits hydrauliques et essais d’étanchéité
- Wiring harnesses and connectors
- Faisceaux électriques et connectique
- Sensor integration and calibration
- Intégration et calibration des capteurs
- Test bench operation
- Conduite des bancs d’essai
- Field maintenance
- Maintenance sur le terrain
PROGRAMME FUNCTIONSFONCTIONS PROGRAMME
- Employment doctrine and user feedback
- Doctrine d’emploi et retour utilisateurs
- Quality and certification
- Qualité et certification
- Patents and export control
- Brevets et contrôle à l’export
- Procurement and supply chain
- Achats et chaîne d’approvisionnement
- Health, safety and environment
- Hygiène, sécurité et environnement
- Training and customer support
- Formation et soutien client
We work with universities and laboratories on doctoral and post-doctoral positions, and we take engineering and technical interns on real subtasks of the programme rather than on side projects.Nous travaillons avec les universités et les laboratoires sur des postes doctoraux et postdoctoraux, et nous accueillons des stagiaires ingénieurs et techniciens sur de vraies sous-tâches du programme plutôt que sur des sujets annexes.
We are open to partners.Nous sommes ouverts aux partenariats.
At this stage of the programme, partners shape the product. We want to work with armed forces and civil security agencies willing to define operational requirements with us, and with industrial and academic partners across actuation, power, communications and embedded AI. Locomotion, perception and mission autonomy are developed within the ZEE group, alongside the sovereign embedded AI and autonomous maritime programmes.À ce stade du programme, les partenaires façonnent le produit. Nous voulons travailler avec des forces armées et des agences de sécurité civile prêtes à définir le besoin opérationnel avec nous, et avec des partenaires industriels et académiques sur l’actionnement, l’énergie, les communications et l’IA embarquée. La locomotion, la perception et l’autonomie de mission sont développées au sein du groupe ZEE, aux côtés des programmes d’IA embarquée souveraine et de systèmes maritimes autonomes.
Technical dossiers, design reviews and demonstrations are available to qualified counterparts under a confidentiality agreement.Les dossiers techniques, les revues de conception et les démonstrations sont accessibles aux interlocuteurs qualifiés sous accord de confidentialité.
Get in touchNous contacter Discuss a partnershipDiscuter d’un partenariat